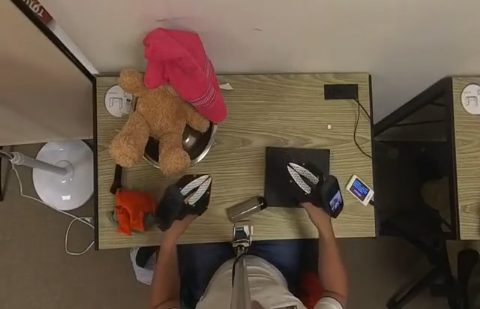
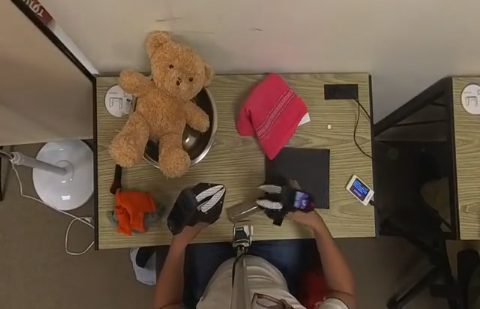
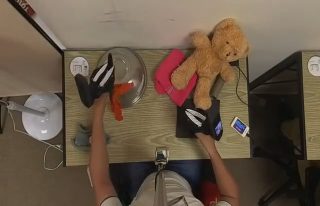
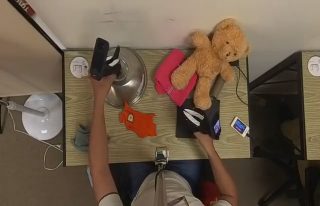
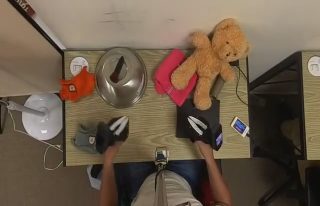
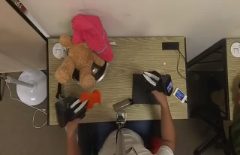
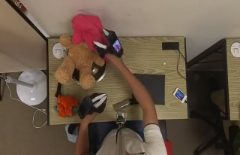
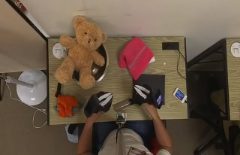
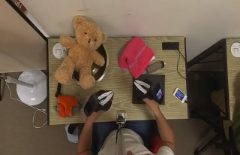
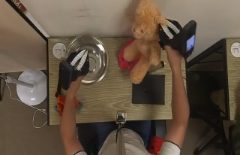
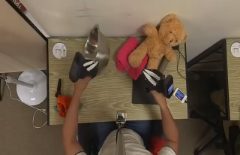
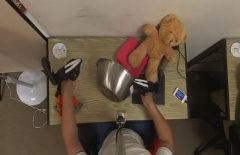
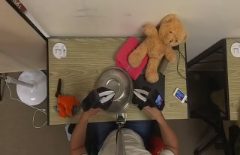
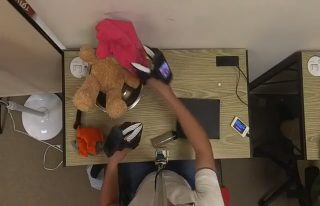
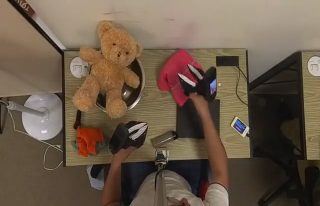
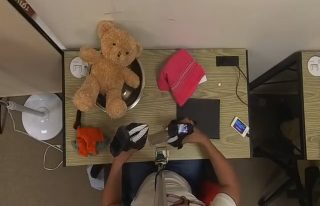
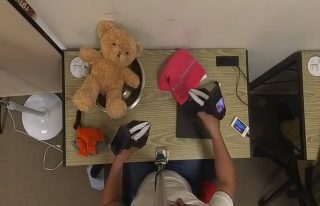
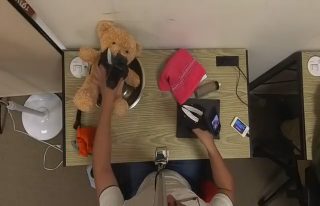
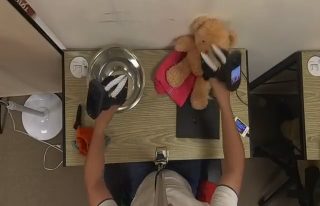
1 · Put both toy shirts together at the front-left
Tasks
Every task attempted in an episode, in plain language, with where it starts and ends and whether it succeeded.
Argus is our open-source annotation and data quality pipeline. It densely labels every episode end-to-end, capturing action phases, key events and more.
Argus labeled every episode of our open-source dataset, DiverseUMI-100, from the tasks attempted to every action and state change.
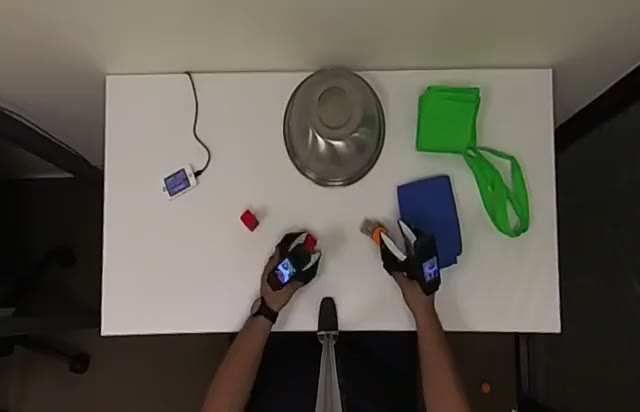
Argus produces a full timeline of actions, state changes, failures and recoveries for each recording.
Every task attempted in an episode, in plain language, with where it starts and ends and whether it succeeded.
Each arm's actions throughout the episode and its contribution to task progression.
What changed in the scene and when: an object moved, opened, stacked or knocked over, and where it ended up.
Every missed grasp, drop and failed placement, when it happened, and how the operator recovered from it.
Most of Argus' accuracy gains come from our harness, not the underlying model: what it sees, what it is asked, and how outputs are checked.
LeRobot, MCAP, plain video and archives, split into episodes by exact timestamps and labeled as recorded.
A quick pass picks what needs fine detail. Grasps, releases and the first and last frames are always seen at full resolution.
Argus knows how each camera is mounted, and reports a change in the scene only when a fixed view confirms it.
Labels are checked against recorded motion and physics, with deterministic checks for sped-up and swapped streams.
We audited nine open-source datasets and found potentially misleading errors in as many as half of a dataset's episodes.
| Issue | OpenAoE | MolmoAct2 | RealOmin | Galaxea | FastUMI-100K | Gen-HumanEgo | Egocentric-100K | HABIT | ABC-130k |
|---|---|---|---|---|---|---|---|---|---|
| Instruction doesn't match the footage | 50% | 20% | 12% | 20% | 7.8% | 10% | · | 2.9% | 2.2% |
| Recorded motion disagrees with the video | · | 0.2% | 6.4% | 0.4% | 6.0% | · | · | 1.6% | · |
| Recording plays faster than real time | · | 23% | · | · | · | · | · | · | · |
| Goal undone before the recording ends | · | 1.9% | 1.8% | 10% | · | · | · | · | · |
| Head camera taken off | · | · | · | · | · | · | 8.9% | · | · |
| Long idle stretches | · | 0.4% | 4.6% | 0.9% | 0.1% | · | · | · | · |
We help our partners annotate and audit their datasets using Argus. Tell us about yours.
Introducing Argus, an open source dataset-and-format-agnostic harness for the densest annotation of robot learning data.
Read the articleWe found recurring quality problems during an audit of popular public robotics datasets, and are releasing a manifest of the results.
Read the article