

Stack
Balancing a clip on a cradle
Freeform
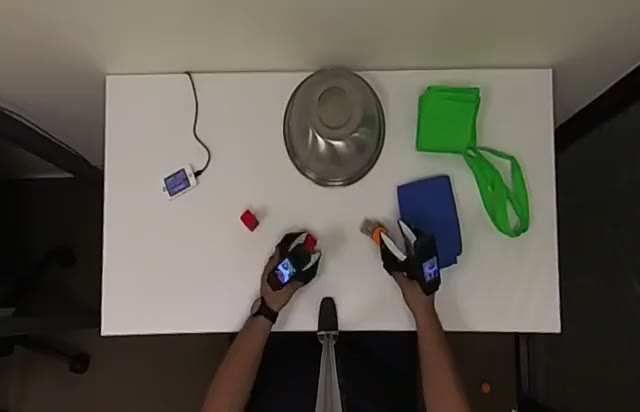
Operators get around 15 objects on a table and perform any tasks they like with no script, and Argus labels the tasks afterwards.
The most task-diverse and environment-diverse UMI dataset in robotics, collected across hundreds of real tables and fully annotated with dense task labels from Argus.
We collect DiverseUMI in several ways at once, each tuned for maximum diversity and efficiency.
Operators get around 15 objects on a table and perform any tasks they like with no script, and Argus labels the tasks afterwards.
The same freeform setup, with episodes full of missed grasps, drops and failed tasks, along with the recoveries that follow.
99% of tasks never repeat. Failures are collected on purpose, and 88% end in a recovery.
Pick and place split by what else happens in the task.
Found in 83% of recordings.
From a handful of objects on a table to more than sixty.
Each square is 1% of tables.
Every episode is densely annotated by Argus, down to each gripper's opening and 6-DoF pose.
For a larger portion of DiverseUMI: we work with commercial and academic labs on joint research and data collaborations.
Contact usHow we scaled UMI collection to over one million unique tasks in eight weeks and optimized costs down to $10 per recorded hour.
Read the article DiverseUMI-100 Open sourceIntroducing Argus, an open source dataset-and-format-agnostic harness for the densest annotation of robot learning data.
Read the article Argus on GitHub Open source